hi_filter_2d_config
Description
Defines the 2D convolutional filtering parameters.
Definition
typedef struct {
    hi_double filter[5][5];
    hi_size kernel_size;
    hi_point anchor;
    hi_double delta;
    hi_vpc_bord_type border_type;
    hi_vpc_scalar scalar_value;
    hi_u32 reserved[2];
} hi_filter_2d_config;
For details about basic data types hi_u32 and hi_double, see Basic Data Types.
Members
Member |
Description |
|---|---|
filter |
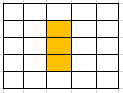
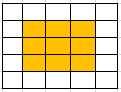
User-defined convolution kernel. Since the filter is a 5 × 5 array, when the width or height within the kernel_size is not 5, the intermediate data within the two-dimensional array is valid, for example: |
kernel_size |
Size of the convolution kernel. The width and height of kernel_size can only be set to 1, 3, or 5. For details, see hi_size. |
anchor |
Convolution kernel anchor, which needs to be set to (-1, -1). This field is reserved. For details, see hi_point. |
delta |
Incremental value, which is added to each pixel value after convolution. |
border_type |
Border making type. Only the HI_BORDER_CONSTANT and HI_BORDER_REPLICATE modes are supported. For details, see hi_vpc_bord_type. |
scalar_value |
Border making value. For details, see hi_vpc_scalar. |
reserved[2] |
Reserved. To ensure compatibility in later versions, use the memset structure for resetting and initialization. Do not explicitly access the reserved field in the code. |